Overview
Provide mobile measurement support for cargo-height inspection.
How it works
The phone captures colour, depth and camera pose. Cargo segmentation isolates cargo points in a metric world frame, while valid scene depth outside the cargo supports a local floor estimate. Cargo top and floor share the same vertical reference; their difference gives height. The capture app sends observations to the backend and receives the measurement result.
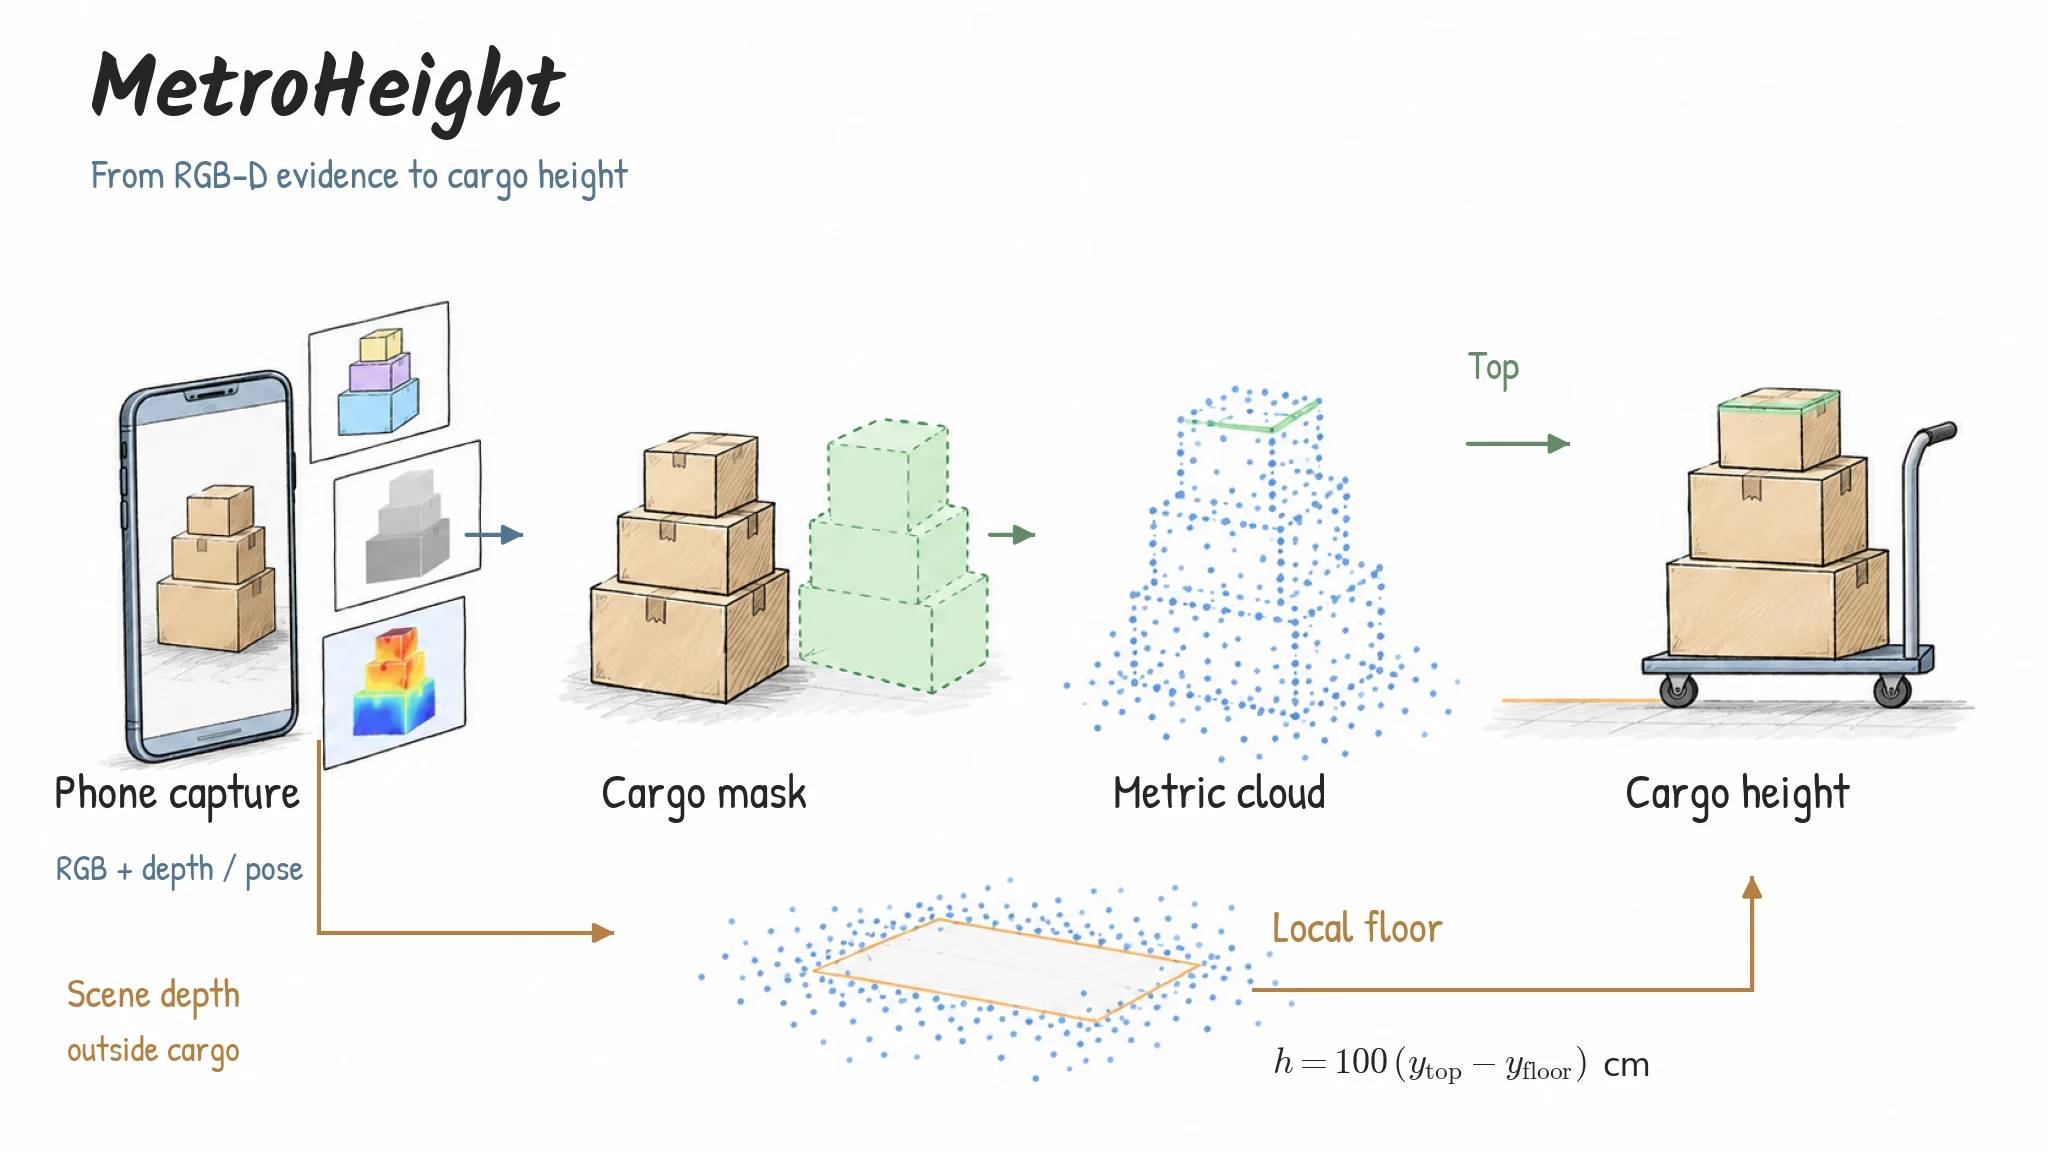
Cargo segmentation and scene depth support separate top and floor estimates in a shared metric reference. Height is measured above the local floor, not above the trolley platform.
AI-assisted method illustration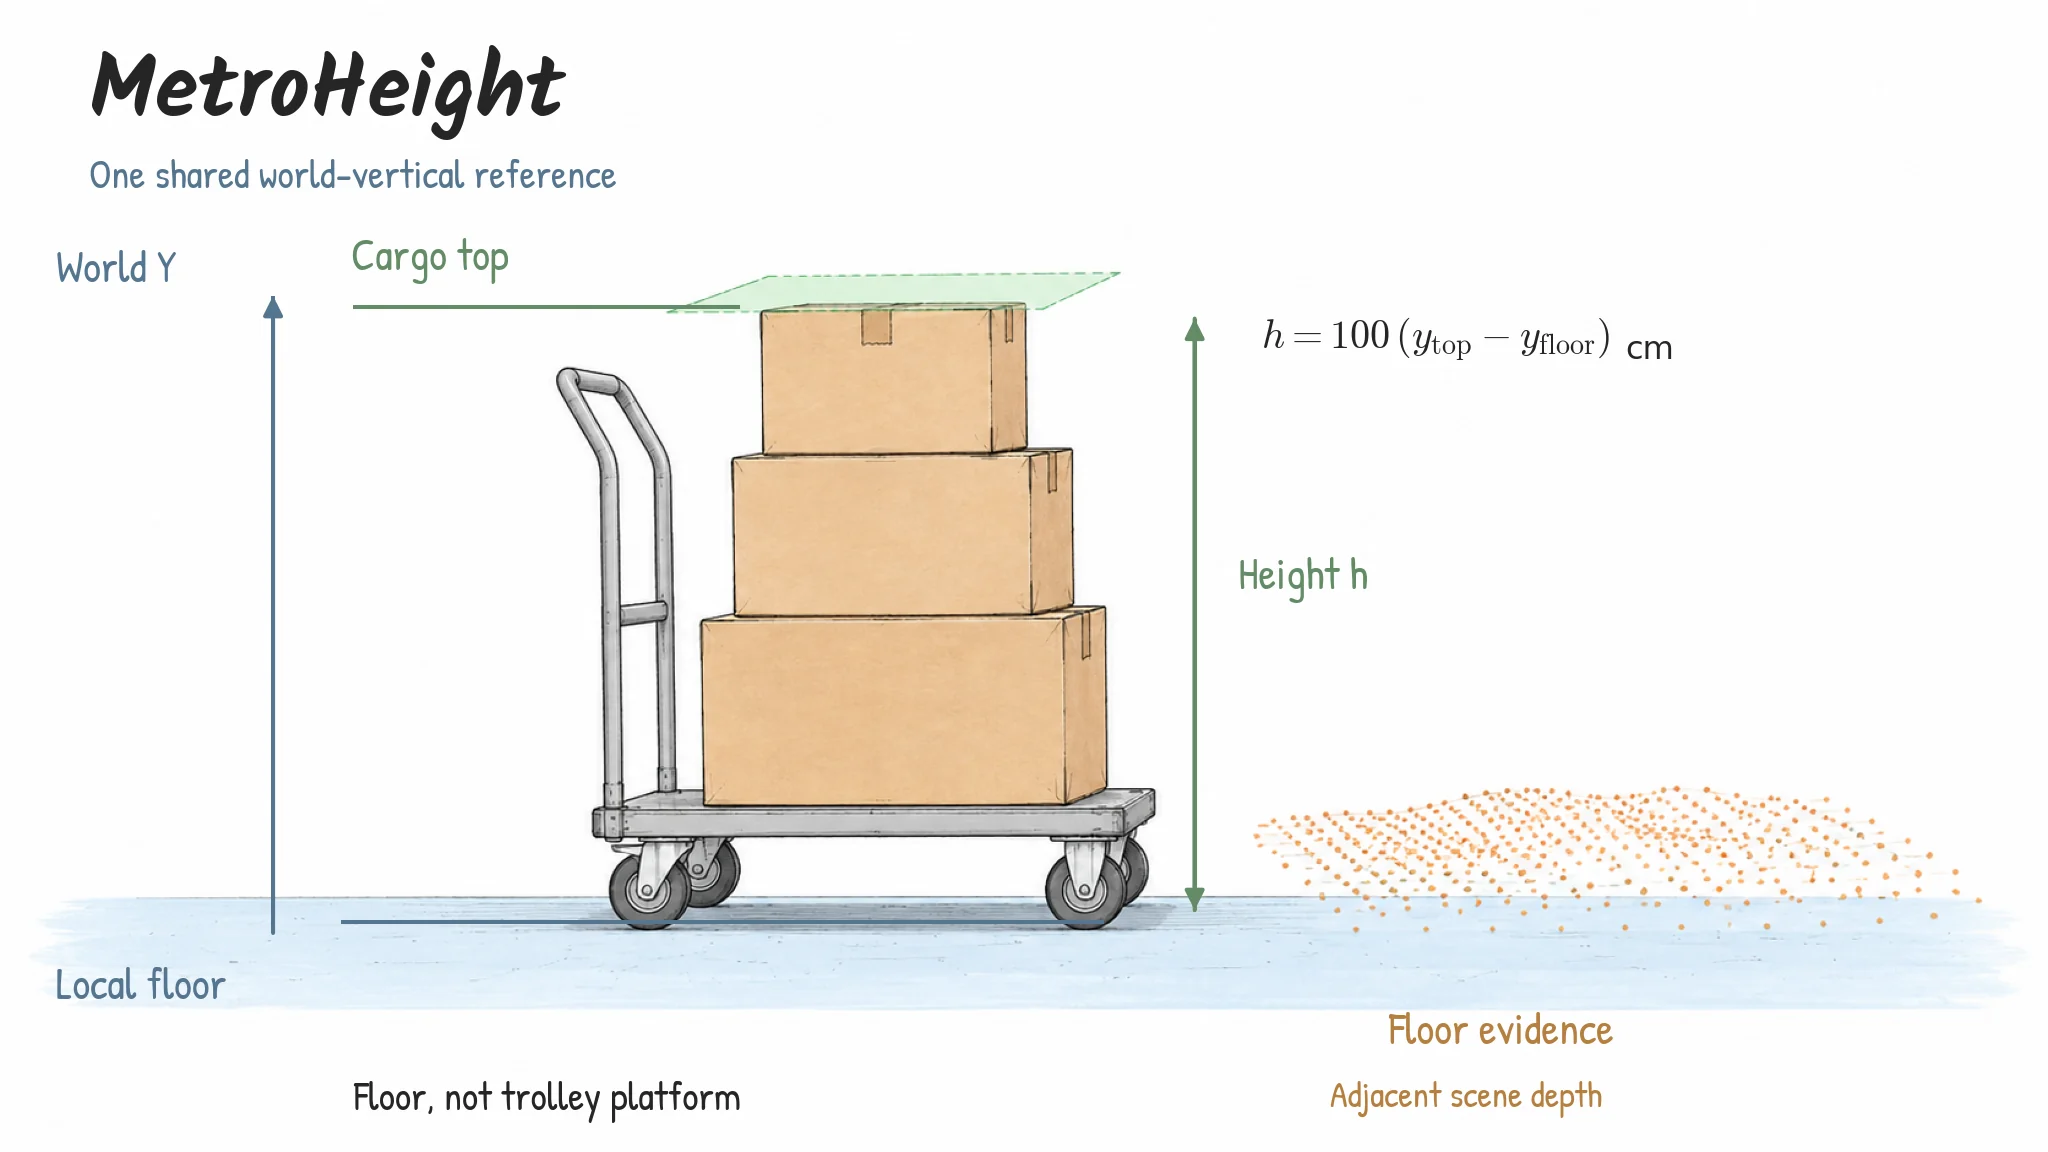
The cargo top and neighbouring floor use the same world vertical coordinate. This schematic explains the geometric definition; it is not a measured sample or a result plot.
AI-assisted method illustration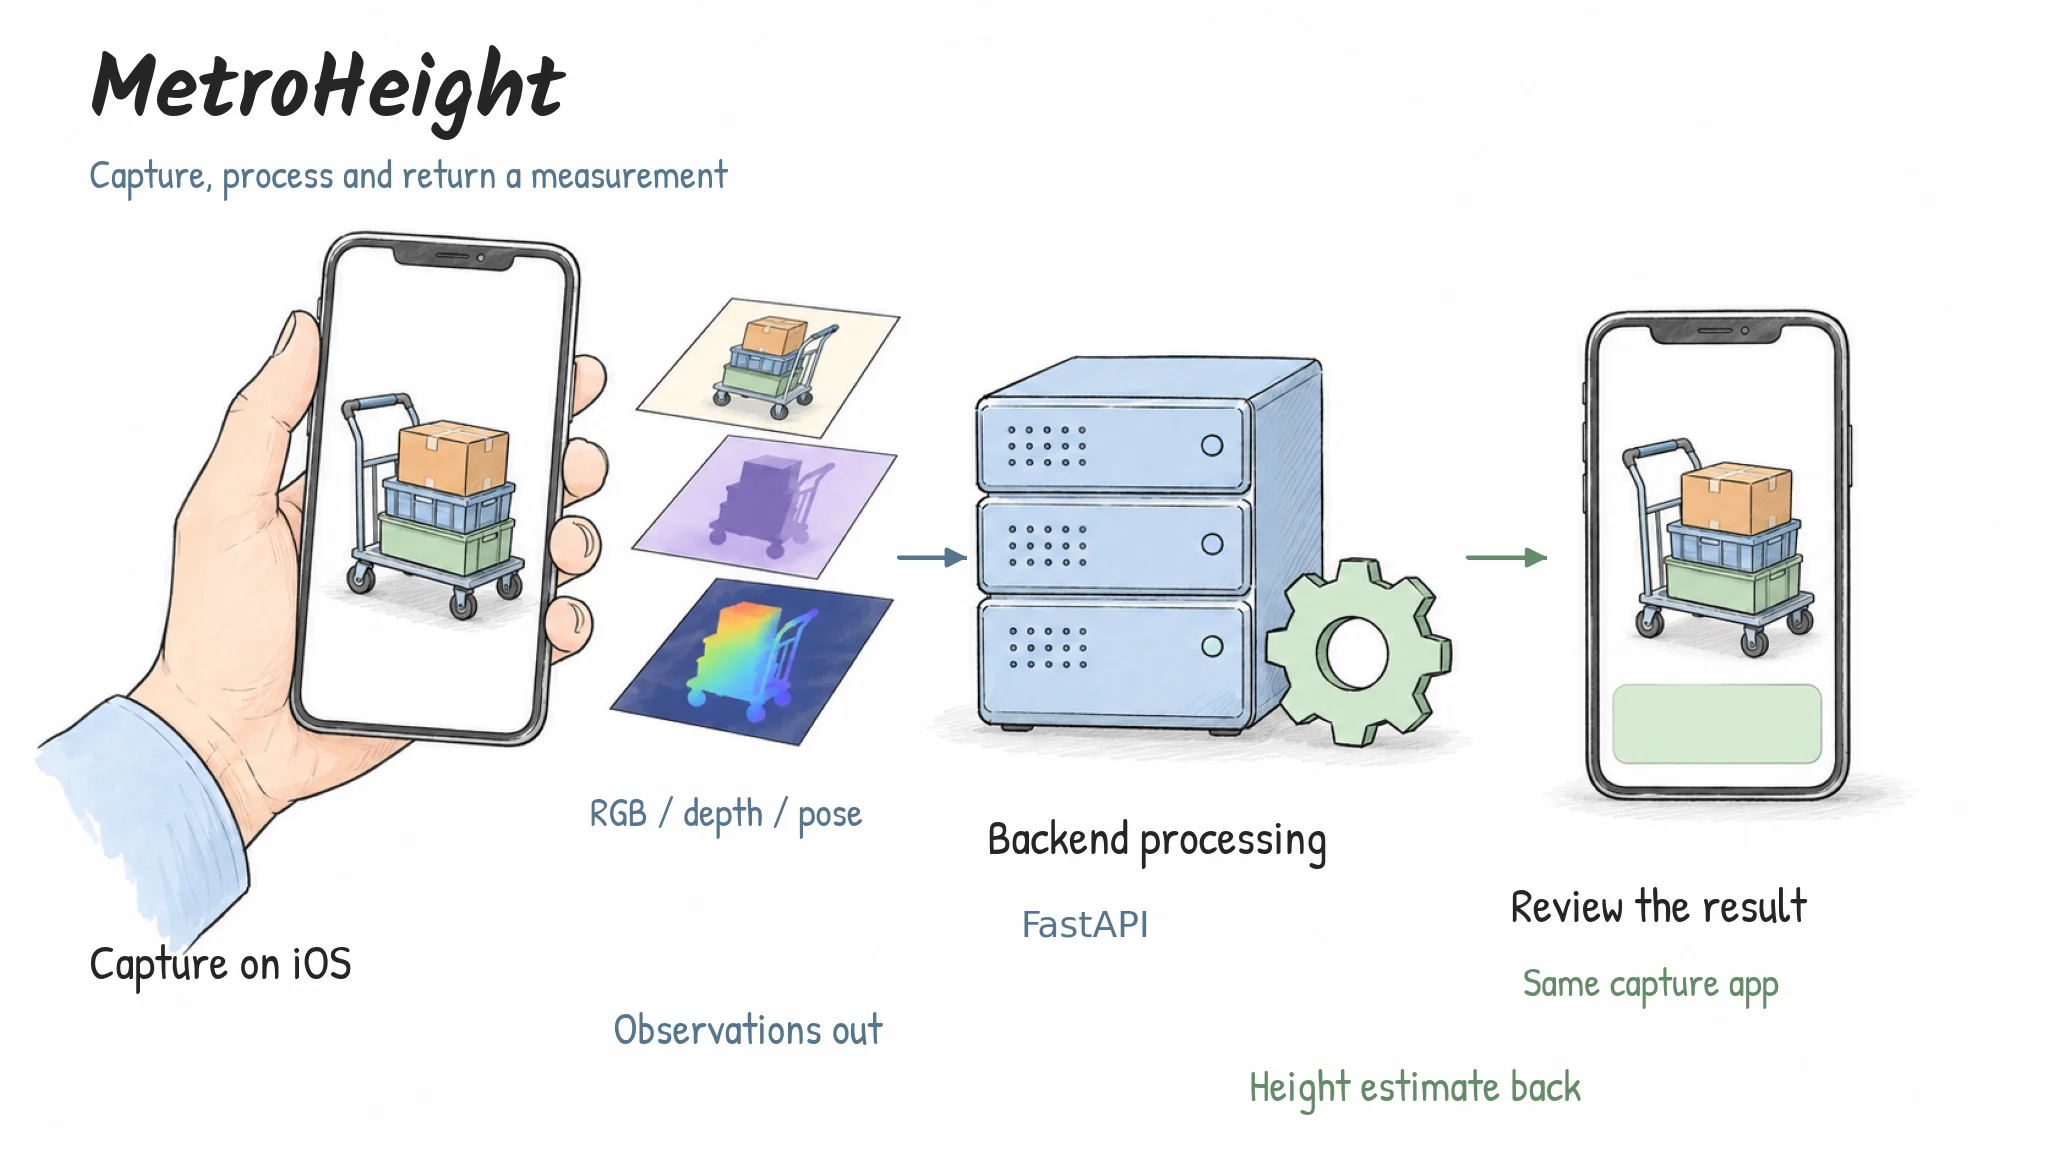
The mobile capture app packages colour, depth and pose observations for backend processing, then displays the returned height estimate.
AI-assisted method illustrationSelected contributions
- Built an iOS capture app and FastAPI backend for the measurement workflow.
- Developed cargo-height estimation from smartphone colour and depth data.
- Evaluated 194 capture records across four trolley categories at Wong Tai Sin Station against laser references.
Research status
First author of “MetroHeight: Smartphone RGB-D Measurement of Cargo Height in Metro Stations”; manuscript in preparation for submission to ACM SenSys 2027.